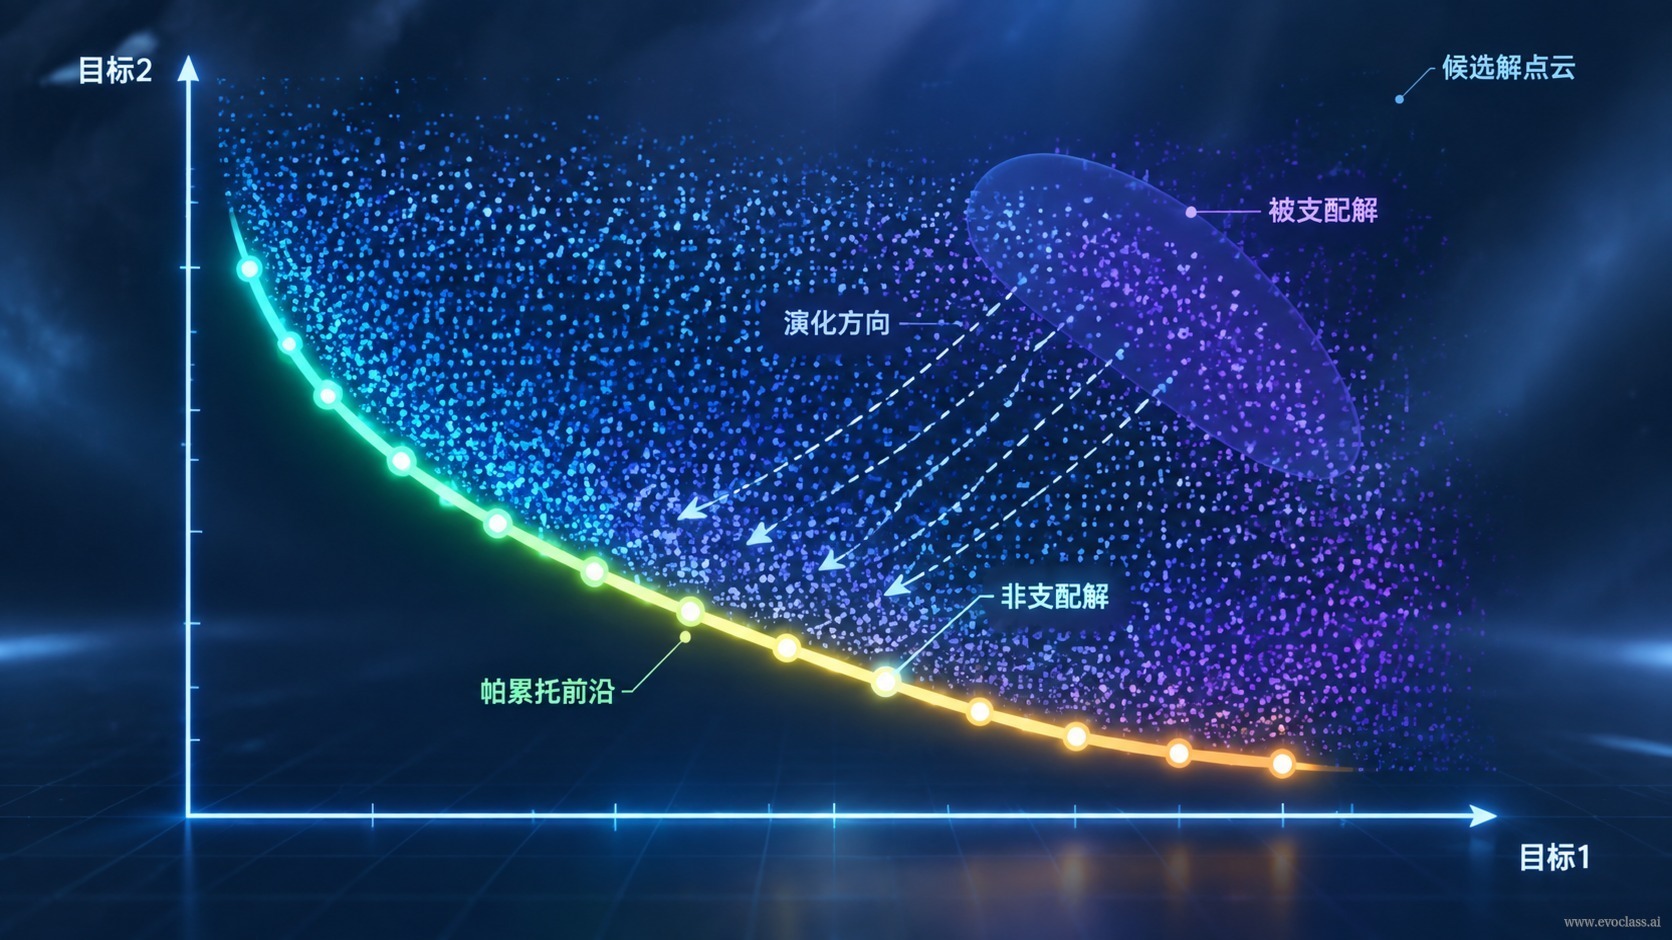
Only when a problem has a single objective can we speak of "finding one optimal solution." Real-world engineering problems are almost never like this: increasing lift tends to raise drag, and improving precision tends to increase cost and latency.Multi-objective conflictmeans a "good answer" is no longer a single point, but an entire set of mutually irreplaceable trade-off solutions—together they form the Pareto front.
From "Single-Point Optimum" to "Trade-off Solution Set"
Denote the two objectives to be optimized simultaneously as f1(e.g., drag, cost, latency) and f2(e.g., structural weight, energy consumption). If solution A is no worse than solution B on all objectives and strictly better on at least one objective, then A dominates B; dominated solutions have no retention value. Conversely, when neither of two solutions can dominate the other, they are mutually non-dominated, and both may remain in the final result. All mutually non-dominated solutions constitute the Pareto front.
Each position on the front corresponds to a "bias": the further toward the upper left, the more it favors pressing f1 down while accepting a larger f2; the further toward the lower right, the opposite. What the decision-maker truly needs is the entire trade-off space represented by the front, not a single point that the algorithm picks out for them.
Diversity: Why "Mutually Distinct" Candidates Must Be Retained
- Directional coverage: Only by searching simultaneously along different trade-off directions can the upper-left end, the middle section, and the lower-right end of the front all be filled, preventing all candidates from clustering in the same corner.
- Difference preservation: Diversity requires not just "more," but "different." Two nearly identical candidates are equivalent to one from the decision-maker's perspective and provide no new trade-off information.
- Decision value: True preferences are often clarified only after the fact. Keeping a set of distinct candidates makes "re-selecting after adjusting preference weights" nearly cost-free.
Computational Scale Challenges: Diversity Is Not Free
The stronger the diversity, the broader the search space that must be covered, the larger the population size, and the greater the total number of candidate individuals that need to be evaluated. Once objective evaluation relies on high-fidelity simulation—for example, a single high-precision aerodynamic computation for a supercritical airfoil can take hours—the cost per evaluation becomes magnified into the main bottleneck of the entire process.
This creates a structural tension:Broader front coveragerequires more candidates and more evaluations, whileexpensive evaluationsin turn limit the affordable scale. Common approaches include: replacing most high-fidelity evaluations with surrogate models; allocating the limited high-fidelity budget preferentially to the candidates that best expand front coverage; and rebalancing the budget between population size and number of iterations.
Pareto Front and Trade-offsThe figure illustrates the Pareto front relationship under two conflicting objectives: dominated solutions have no retention value, mutually non-dominated solutions are distributed along the front, and the more one leans toward either end, the more it means pressing down one objective while accepting a worse value for the other. What the decision-maker truly needs is the entire trade-off space; retaining candidates with structured variation enables low-cost response to changes in preference, while high-fidelity evaluation cost limits the achievable population and evaluation scale.