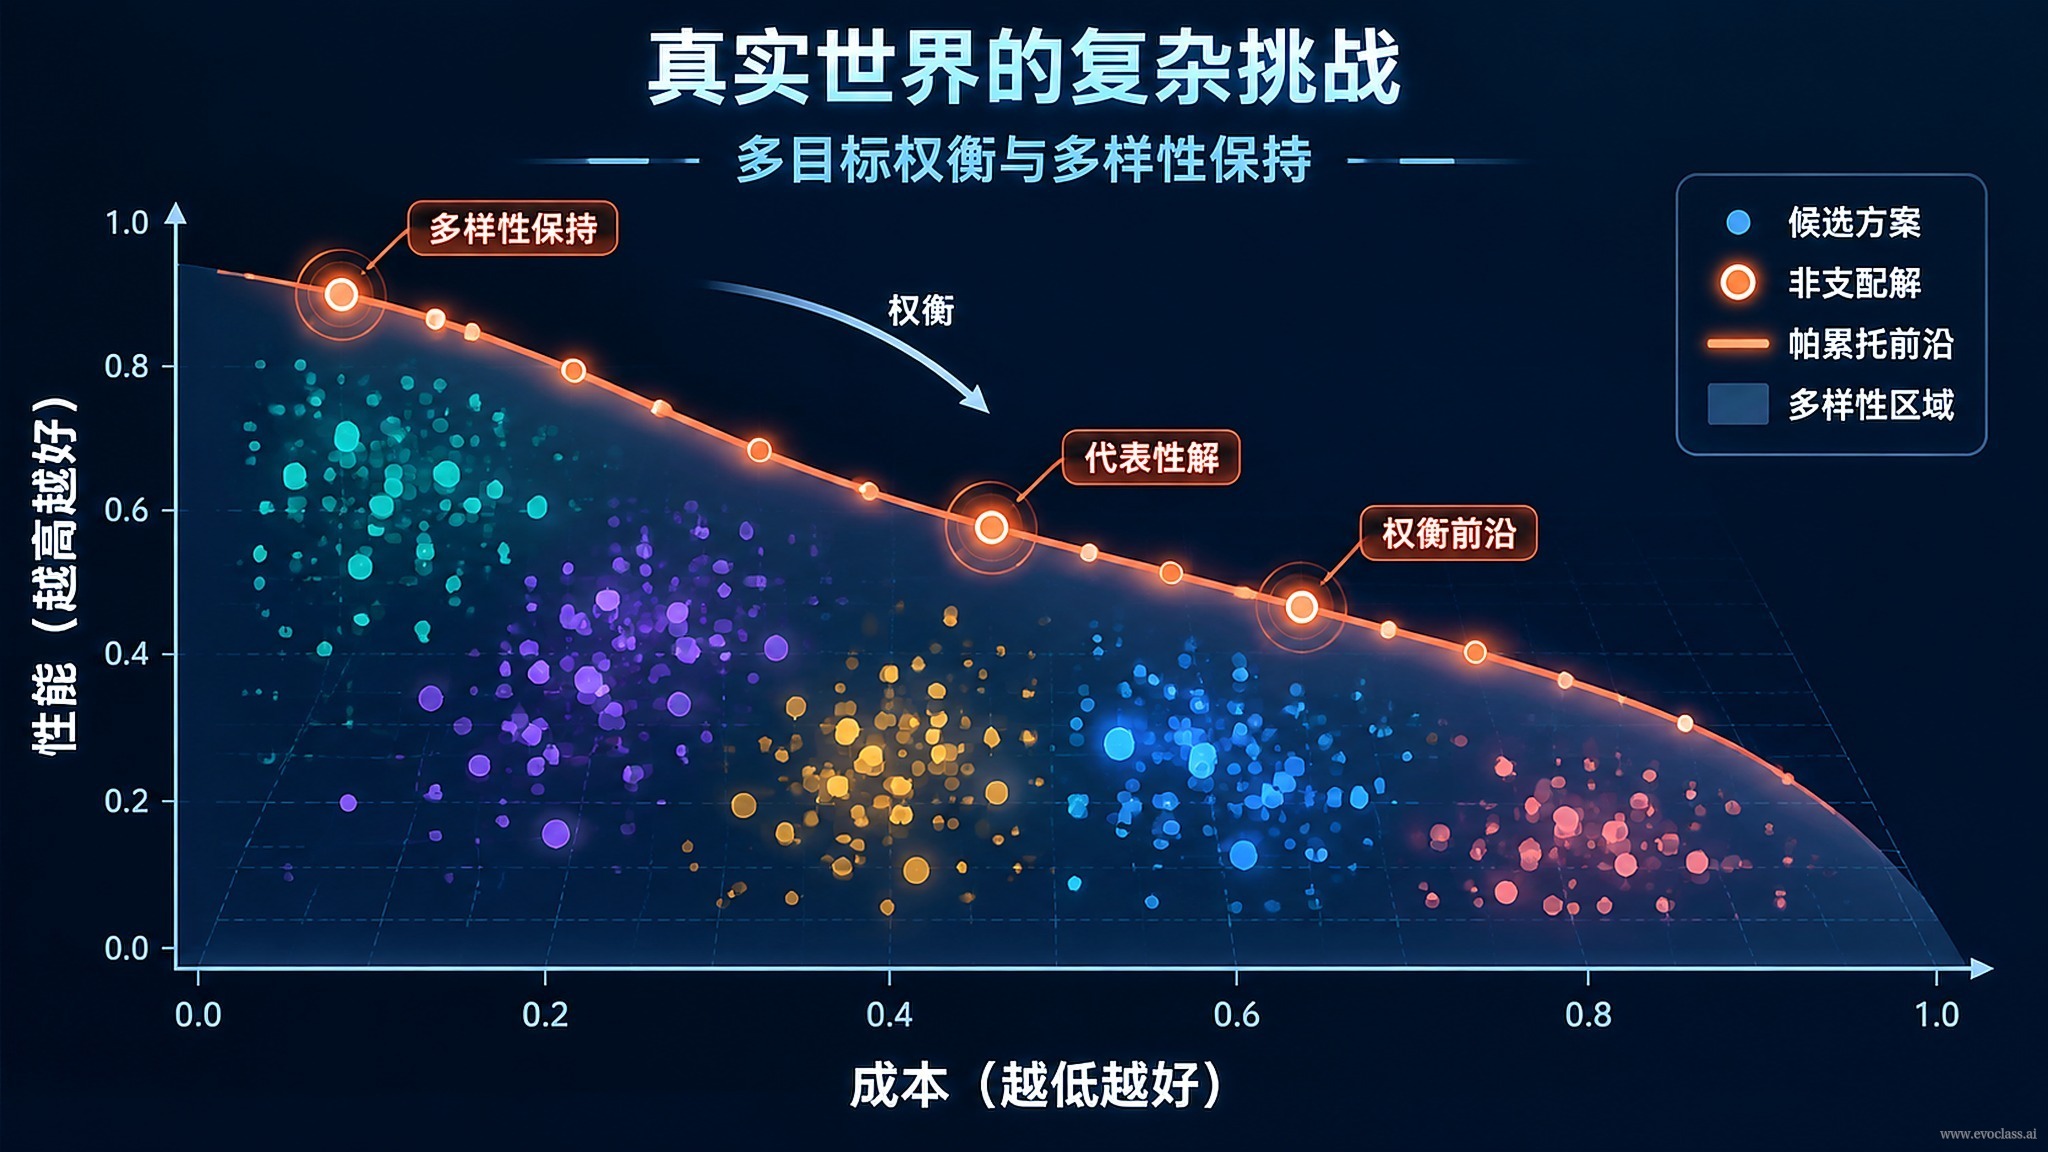
Complex problems in the real world rarely have a single optimal solution. Multiple objectives pull against one another, and improving one metric usually comes at the expense of others. Therefore, rather than converging on a single "optimal answer," a system should retain a diverse set of non-dominated candidates, making trade-offs explicit and keeping the final decision in human hands.
Objective conflicts are structural, not a matter of tuning parameters
Objectives such as lift-to-drag ratio, structural strength, cost, and manufacturability cannot be optimized simultaneously. The trade-off curve (Pareto front) can only be approached, never eliminated. The gray scatter points in the figure represent possible solutions, while the colored points represent mutually non-dominated candidates that together form the front.
There is no total order under multiple objectives
Any two solutions may be mutually non-dominated, and "best" can only be defined with an accompanying preference direction. Strength-biased, efficiency-biased, balanced, and ultra-low-drag options are all reasonable choices under different preferences—not a single ranking list that can be arbitrarily ordered.
Sparse feedback is the norm
In real-world engineering, evaluation relies on costly simulations or physical testing, with few feedback signals, high noise, and no usable gradients, making single-point hill-climbing searches hard to advance effectively. Evolutionary algorithms maintain a population to explore multiple directions simultaneously under limited evaluations, avoiding the risk of staking the entire budget on a single direction.
Diversity is an asset, not a byproduct
A set of candidates spread across different regions of the front is equivalent to leaving the choice and domain knowledge to experts rather than making decisions on their behalf. If only the current optimum is pursued, the population will converge prematurely and collapse in mode, ultimately losing entire unexplored trade-off ranges. The two small panels on the right of the figure illustrate this contrast: single-point convergence collapses into a tight cluster, while diverse distribution spreads out into a front.
A clear division of responsibilities
The algorithm is responsible for "generating a diverse set of usable options," while domain experts are responsible for "completing evaluation and trade-offs based on preferences and constraints." A set of candidate solutions does not make decisions for people but instead puts comparable options on the table.
Engineering Example: Supercritical Airfoil Design
Aerodynamic efficiency, drag divergence characteristics, structural strength, and manufacturing cost all pull against one another. The value of EvoX lies not in providing a single "optimal airfoil" but in outputting a family of candidate airfoils spanning different trade-off ranges, for engineers to select based on specific flight conditions and manufacturing constraints.
Multi-Objective Trade-off Scatter Plot and Candidate Distribution DiagramGray scatter points represent possible solutions, while colored mutually non-dominated candidate points collectively approach the Pareto front; the two small panels on the right contrast single-point convergence collapsing into a tight cluster with diverse distribution spreading out into a front. This illustrates that there is no total order under multiple objectives—only trade-offs accompanied by preference directions—and that algorithms should output candidate sets covering different trade-off ranges rather than a single "optimal solution."