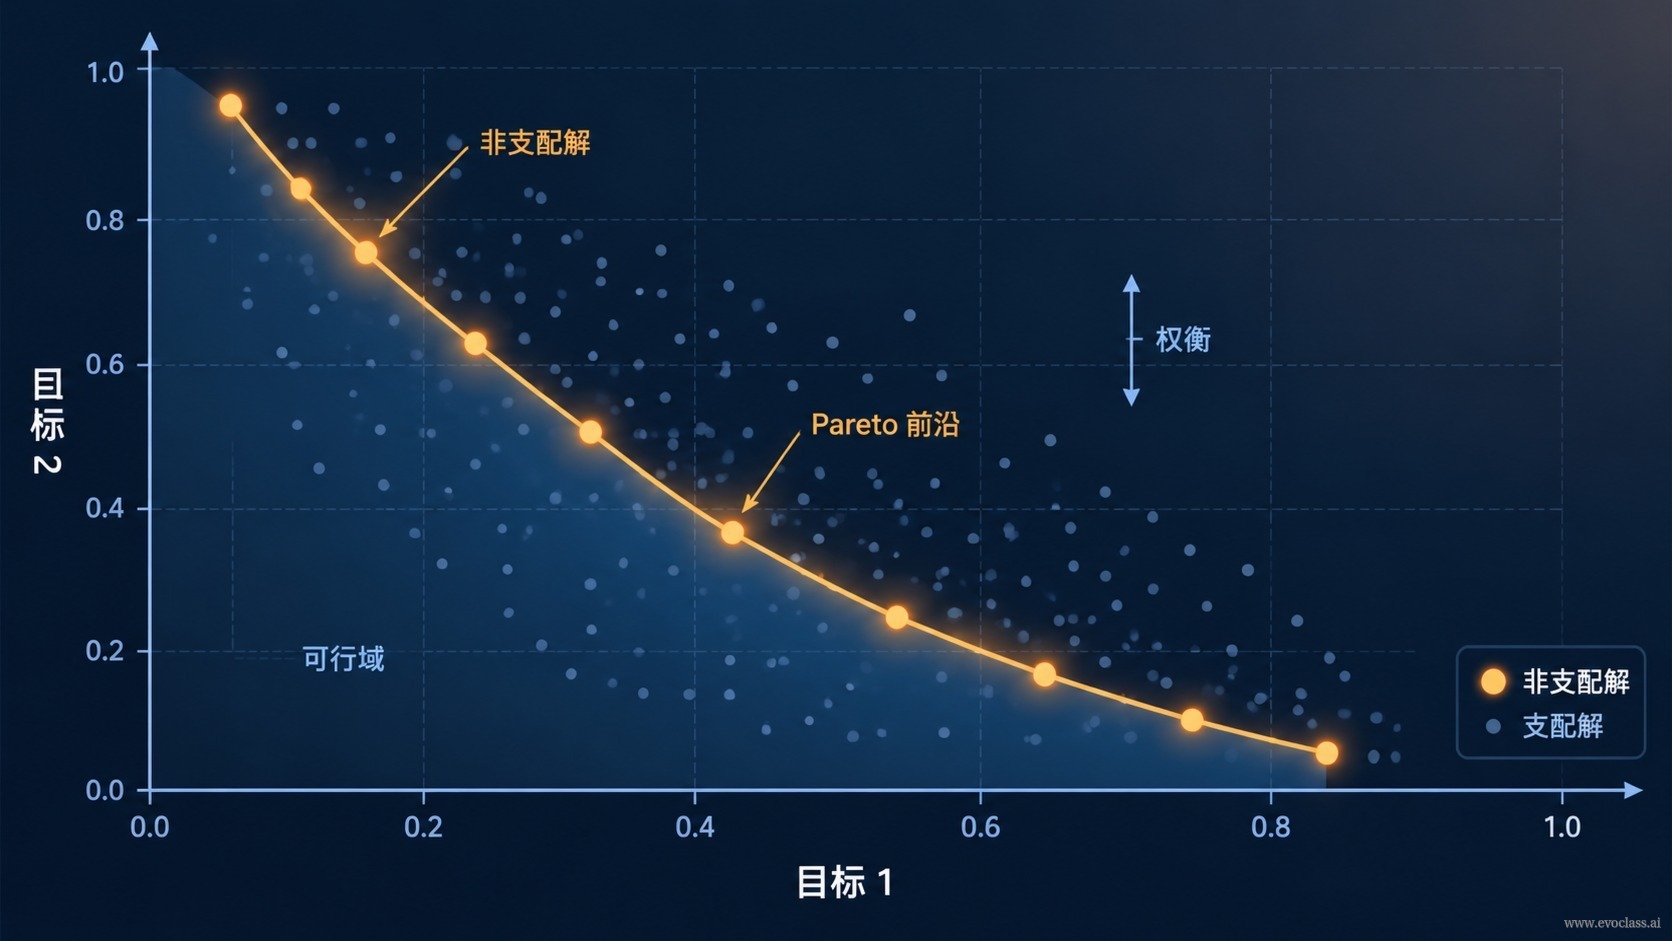
In real-world engineering, there is almost never a "single optimal solution." Take supercritical airfoil design as an example:lift-to-drag ratio, structural strength, stall margin, and manufacturing/simulation cost are all in tension with one another—improving the lift-to-drag ratio often means structural loads and manufacturing costs rise in tandem. The right way to frame such problems is:multi-objective optimizationthe goal is not to pinpoint a single solution, but to characterize and approximate a Pareto frontacross multiple mutually competing objectives, and to retain a set of candidate solutions with different orientations and trade-offs, leaving the final value judgment to downstream preferences or domain experts.
1. First, confirm: is this really a multi-objective problem?
Multi-solution exploration presupposes that the objectives genuinely conflict. If all objectives can be improved simultaneously without trade-offs, the problem degenerates into a single-objective one, and multi-solution exploration is both unnecessary and a waste of computing power. The criterion is not "more than one objective," but rather:does improving one objective necessarily come at the expense of another. Only opposing directions and mutual trade-offs constitute a true multi-objective problem.
2. Pareto Dominance and the Pareto Front
The core criterion is Pareto dominance: Solution A dominates solution B if and only if A is no worse than B on all objectives (fᵢ(A) ≤ fᵢ(B) for every objective i) and strictly better on at least one objective (there exists j such that fⱼ(A) < fⱼ(B)). Any dominated solution has a replacement that is "at least as good and better somewhere," so it has no value in being kept. All solutions that are not dominated by any other solution form the Pareto front—solutions on the front are mutually non-dominated, and which is more suitable depends on preference, not on mathematics.
3. The Cost of Reducing to a Single Objective
Scalarization methods such as weighted sum and ε-constraint compress a vector objective into a single scalar. This is convenient in engineering, but the costs are concrete:
· Masks the trade-off structure—once weights are fixed, the shape of the front and the alternative directions become invisible, and decision-makers see only a single score.
· Weights must be specified in advance—yet real preferences often cannot be formalized in advance and typically only become clear during the review stage.
· Limited coverage—weighted sum typically hits only isolated points on the front, and portions of a non-convex front are difficult to reach.
Once a later review changes the weights, the entire search must be rerun—the exact opposite of "one exploration for many freedoms in decision-making."
4. Evaluation Is Two-Dimensional: Convergence and Diversity
The quality of a multi-objective solution set must be assessed on two dimensions simultaneously:convergence(whether the solution set approaches the true front) anddiversity(whether the solutions cover different regions of the front). The two often pull against each other: once selection pressure leans too heavily toward "better," the population collapses to a single point or a small segment of the front—appearing to converge quickly while losing the trade-off information. It is therefore necessary to explicitly maintain population diversity and to combine selection pressures such as crowding distance, decomposition, and indicator-driven approaches (e.g., hypervolume).
5. Engineering Implication: The Decision Point Shifts
The engineering meaning of multi-objective optimization is a shift in the division of labor: the optimizer is responsible only for producinga comparable set of candidates, and final selection is made by preferences or domain experts. The optimizer should not prematurely converge on the decision-maker's behalf. The practical rationale for retaining a diverse candidate set is "hedging"—when preferences are unknown, may shift with context, or when constraints get revised during deployment, a diverse set of solutions is more valuable than a single "optimal solution." This is consistent with the sedimentation mechanism in which "candidate modifications must pass compilation, testing, and acceptance before being adopted": first retain a set of candidates, then let verification and preferences decide which one enters the final version.
Pareto Front and Dominance RelationsThe scatter plot uses two mutually competing objectives as coordinates, distinguishing dominated solutions from the Pareto front: solutions on the front are mutually non-dominated, so improving one objective necessarily comes at the cost of degrading another. The optimizer therefore outputs a set of candidates with different orientations, leaving the final trade-off to preferences or domain experts.